Online — in real time
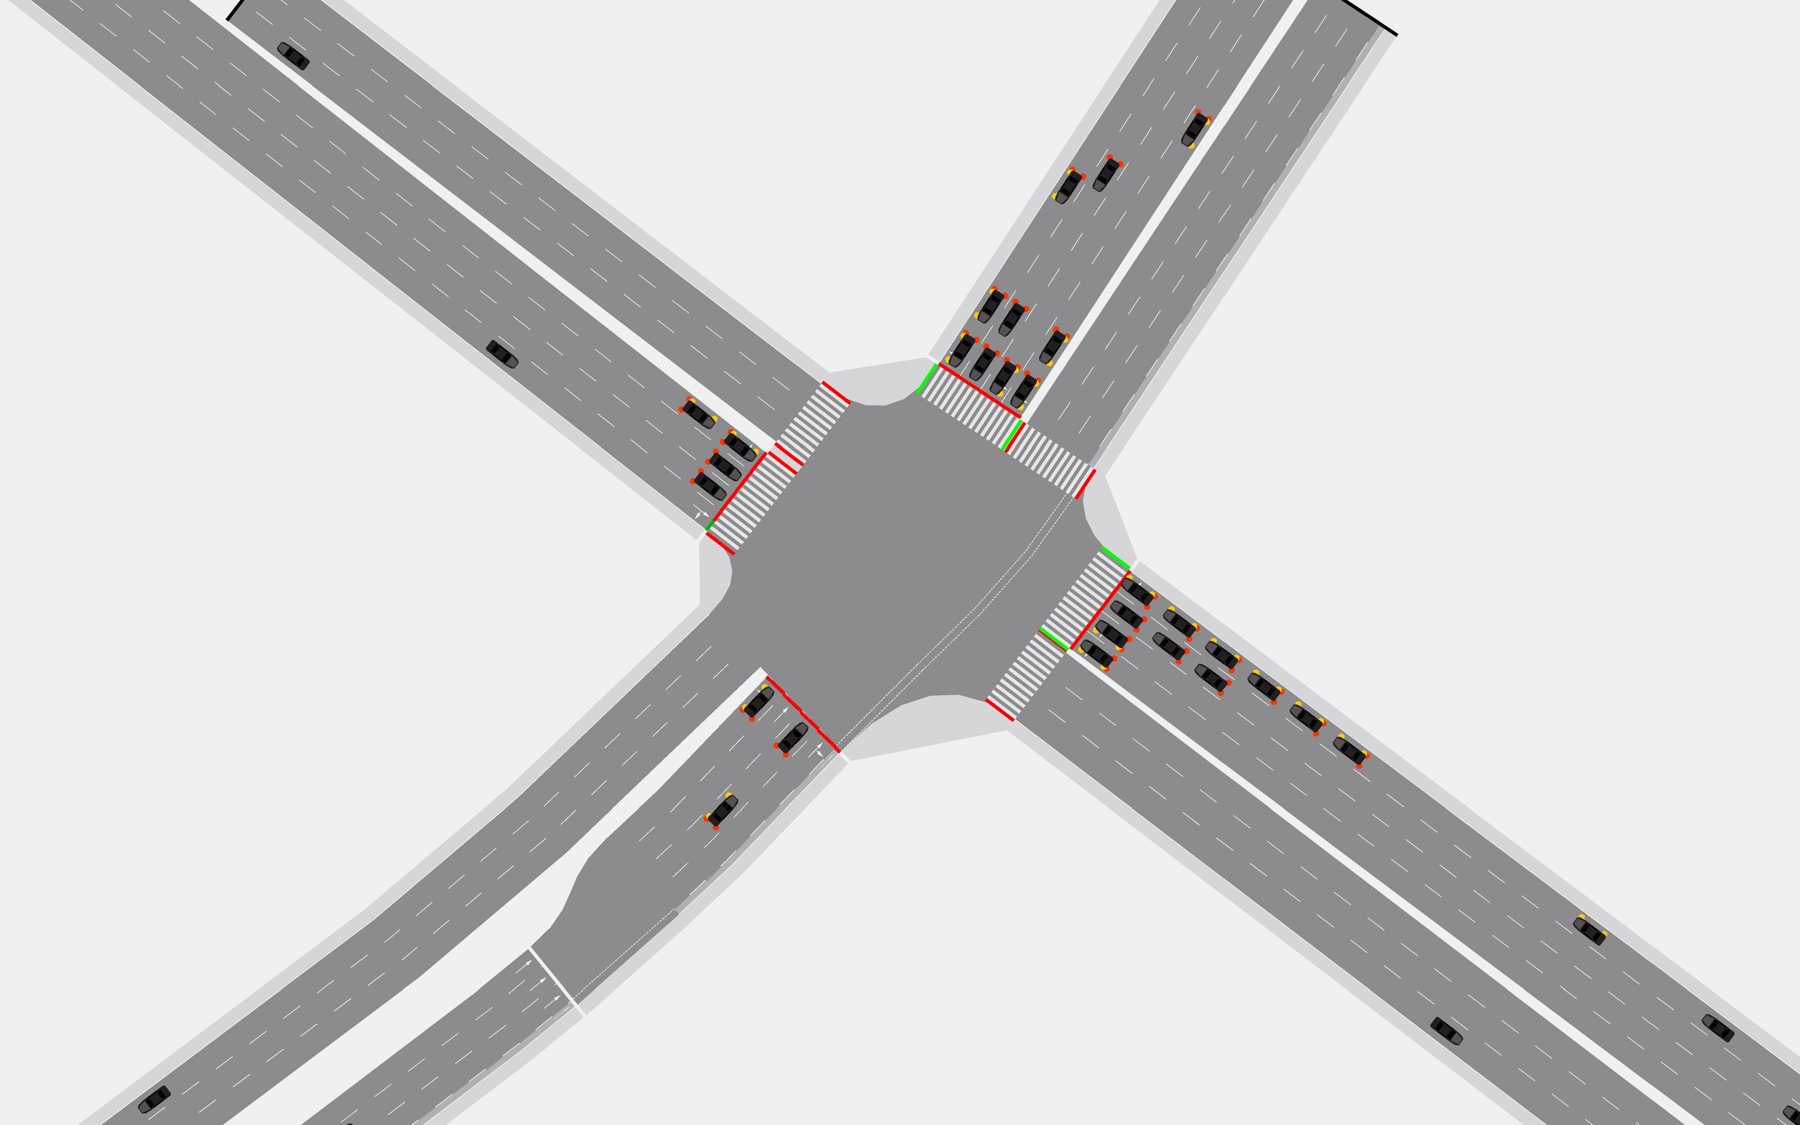
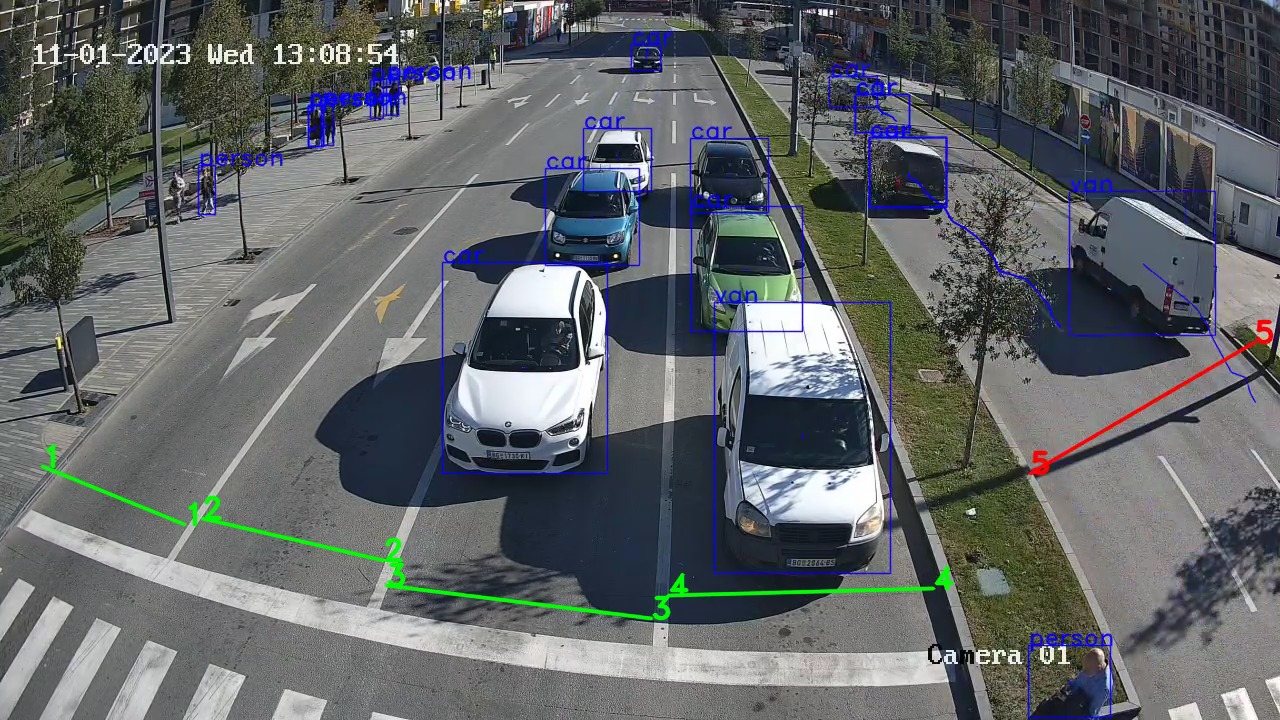
Live detection as input for adaptive control.
- Detection and classification
- Queue length per approach
- Speed and density
Works with PTV Epics and PTV Balance.
A loop sees a point. A camera sees the intersection.
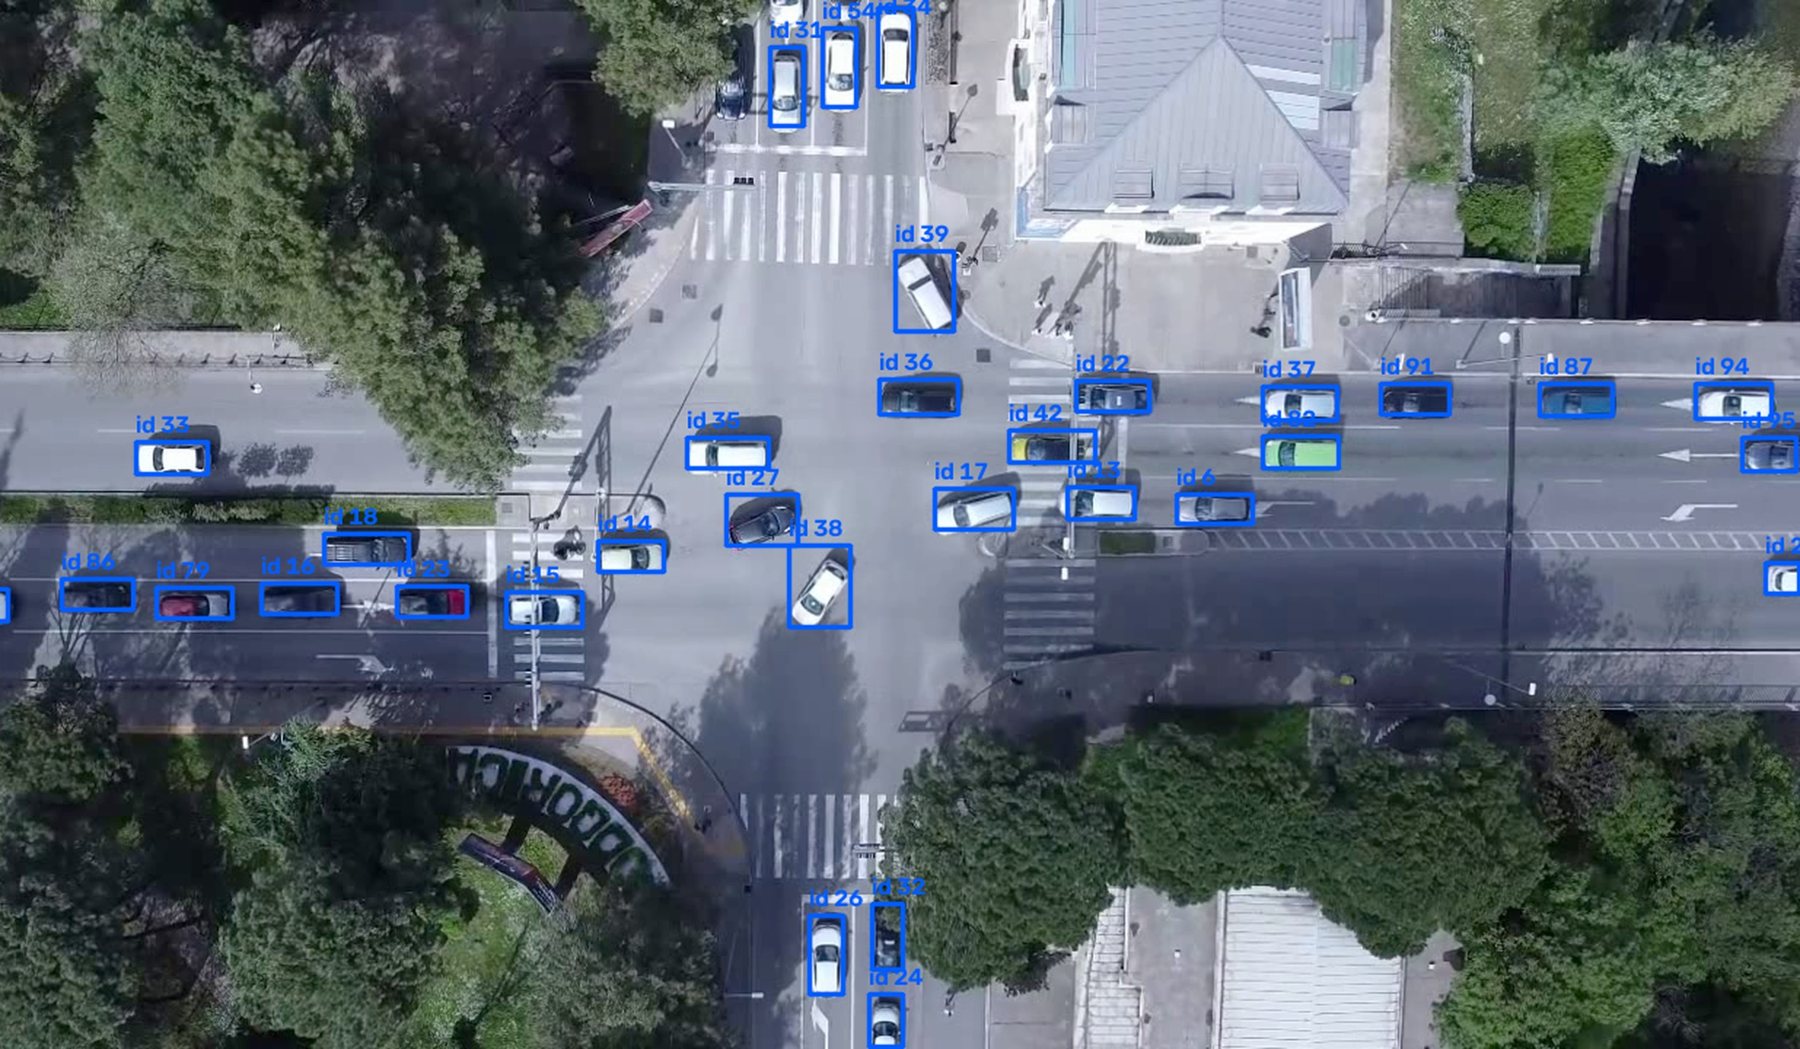
HAWKAI processes live video for real-time traffic control, or recorded video for detailed analysis and strategic planning. It works with fixed cameras on a pole or with a drone, and detects, classifies and tracks every road user in the frame. The output: origin–destination matrices, detections and trajectories, ready for control and planning.
Live detection as input for adaptive control.
Works with PTV Epics and PTV Balance.
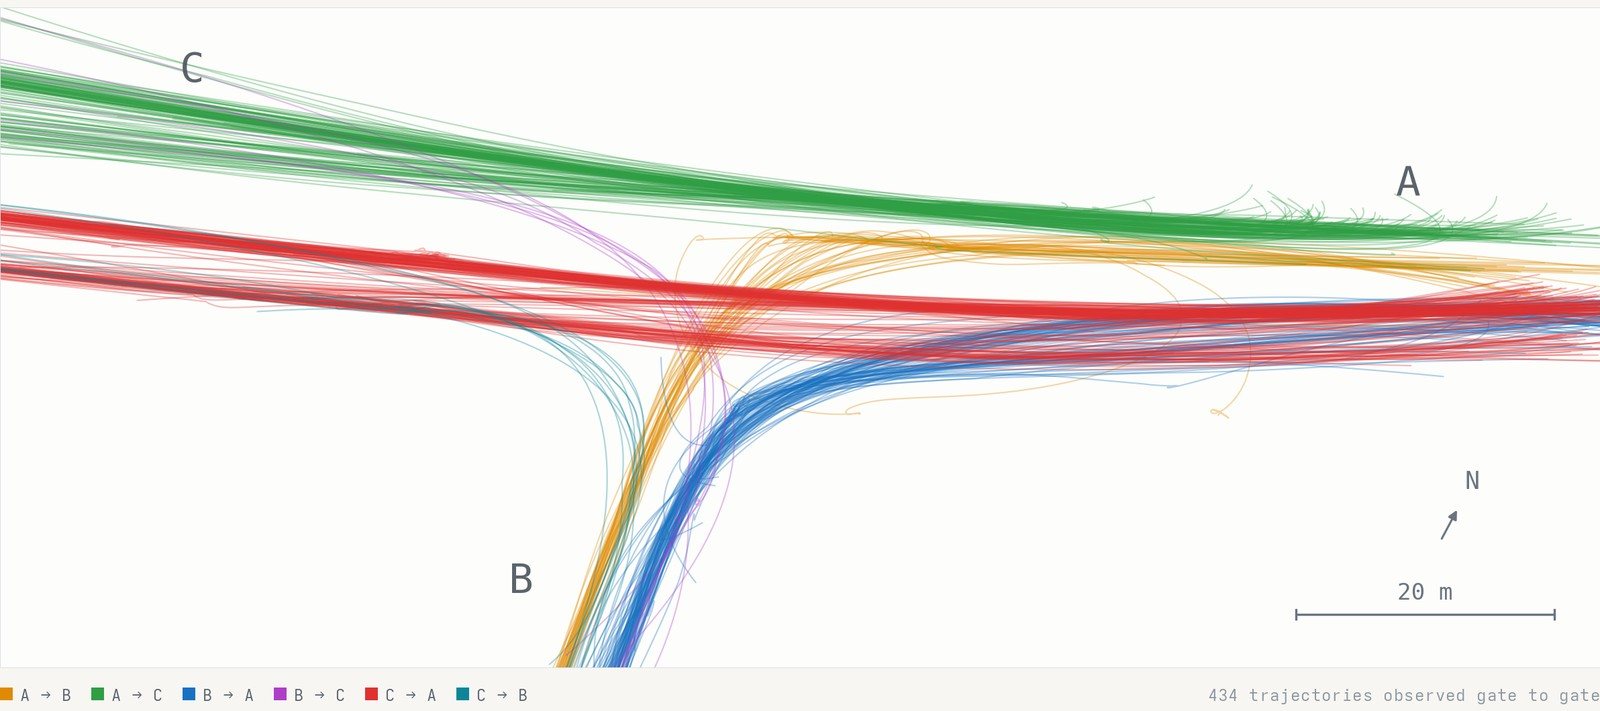
Four cameras merged into one trajectory map for analysis and planning.
Works with PTV Visum, PTV Vissim and LISA.
Sees only the vehicle inside the loop's zone.
Sees the whole approach: every vehicle, the queue and the speed.
Vehicles for each entry–exit pair.
Every path through the intersection, coloured by manoeuvre.
Where traffic actually stands still: queues and conflict zones.
| From \ To | A | B | C | Σ |
|---|---|---|---|---|
| A | · | 54 | 220 | 274 |
| B | 92 | · | 21 | 113 |
| C | 348 | 21 | · | 369 |
| Σ | 440 | 75 | 241 | 756 |